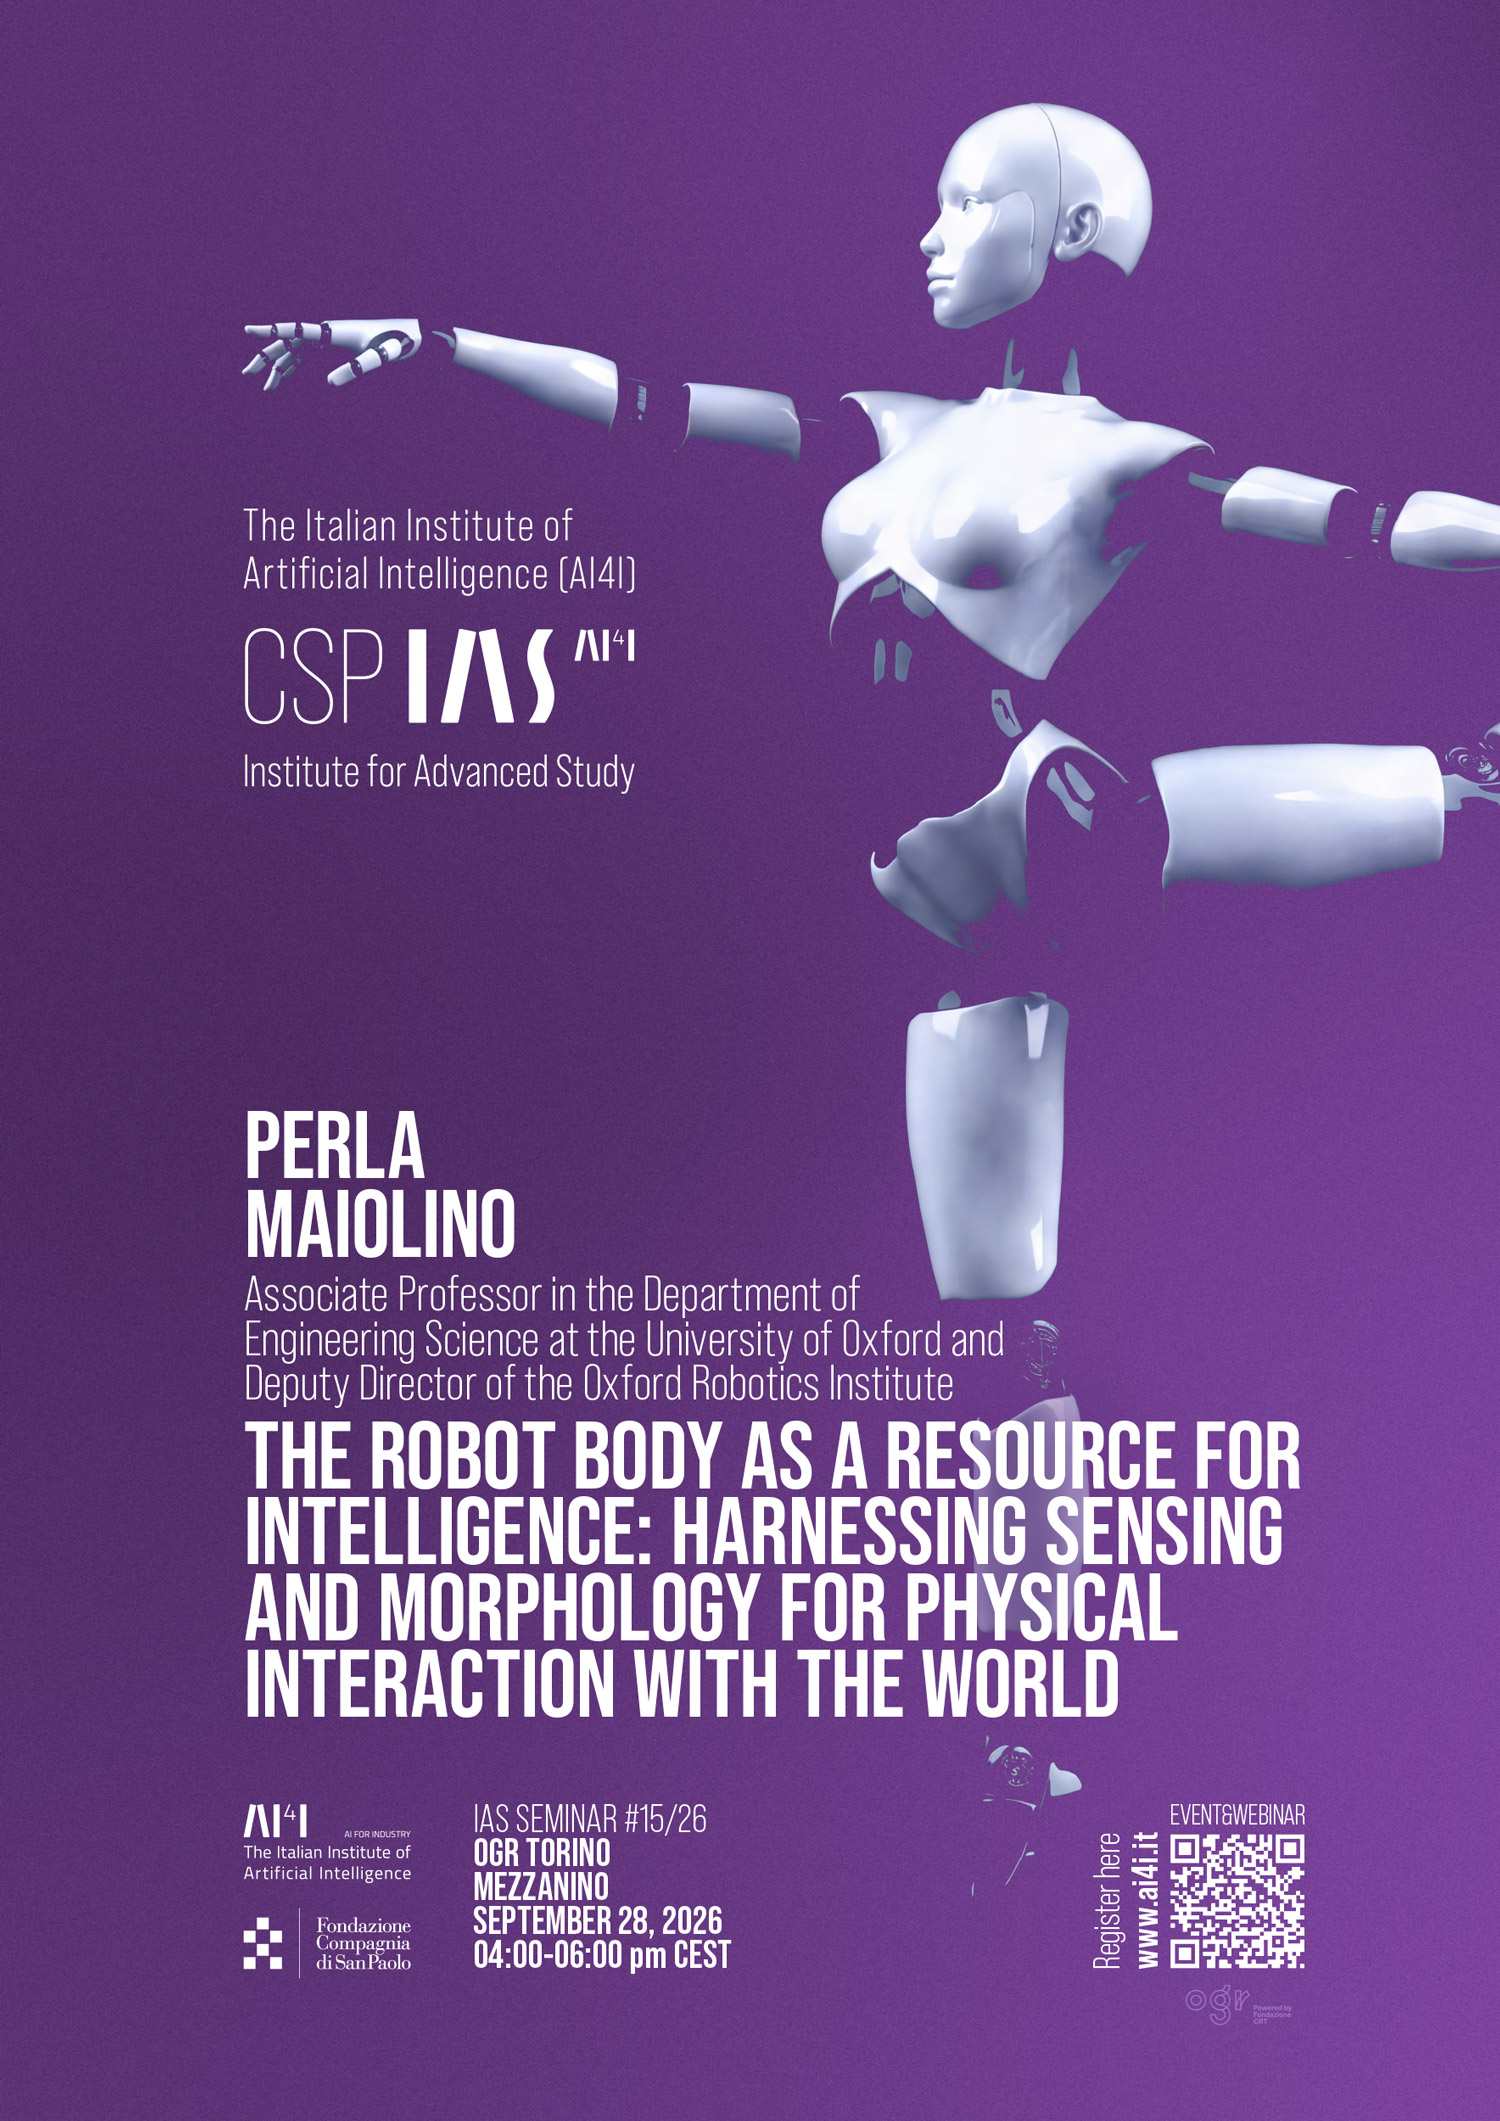
Perla Maiolino
Associate Professor in the Department of Engineering Science at the University of Oxford and Deputy Director of the Oxford Robotics Institute
IAS SEMINAR #15/2026
Turin / OGR / Mezzanino / September 28, 2026 / 04:00 – 06:00 pm CEST
Associate Professor in the Department of Engineering Science at the University of Oxford and Deputy Director of the Oxford Robotics Institute
EVENT&WEBINAR
Recent advances in artificial intelligence are giving robots remarkable capabilities in perception, reasoning and learning. Yet physical interaction remains fundamentally challenging: contact is local and dynamic, the relevant sensory data are difficult to scale, and small uncertainties in the world can produce large consequences during manipulation.
In this talk, I will argue that addressing these challenges requires looking beyond a purely controller-centric view of intelligence. In embodied systems, intelligent behaviour emerges from the interaction between learning, sensing, body morphology, material dynamics and the environment. Drawing on our work in tactile sensing and soft robotics, I will show how distributed tactile and proximity perception can give robots richer awareness of physical interaction; how multimodal learning and synthetic data can address some of the limitations of tactile datasets; and how compliant and nonlinear bodies can simplify control and even implement elements of computation through their physical dynamics.
I will then reverse the perspective and discuss how AI can be used to design embodiment itself, using surrogate modelling, optimisation and task-driven design to discover robot morphologies and sensing configurations adapted to their function. Together, these examples invite us to reconsider the role of the body in artificial intelligence: not simply as the physical platform on which intelligent algorithms operate, but as an active part of the sensing, learning and interaction processes that give rise to intelligent behaviour.
PERLA MAIOLINO
Perla Maiolino is an Associate Professor in the Department of Engineering Science at the University of Oxford and Deputy Director of the Oxford Robotics Institute, where she leads the Soft Robotics Laboratory.
Her research focuses on soft sensing, actuation, and embodied intelligence, with the goal of understanding how mechanical properties and morphology can contribute to perception and control in robotic systems. She received her B.Eng., M.Eng., and Ph.D. in Robotics from the University of Genoa.
Her work has contributed to advances in tactile sensing, integrated soft robotic systems, and multi-material fabrication, including the development of CySkin. She serves as Associate Editor for IEEE Robotics and Automation Letters and Soft Robotics, and has held key roles in the robotics community, including in the organization of the IEEE RoboSoft conference. She was also an invited keynote speaker at IROS 2025. Her research has been featured in major public-engagement initiatives, including the BBC Royal Institution Christmas Lectures.
Joining us in person offers the opportunity for direct networking and interaction with both speakers and participants.
Please complete the form below to reserve your seat.
By clicking, you will be automatically registered for the in-person event.
Note: If you see a message saying you’re already subscribed, please ignore it — your in-person registration will still be confirmed.
Please note that, by attending, you implicitly authorize AI4I to film and photograph the audience during the seminar. By submitting your registration, you acknowledge and accept the AI4I Data Privacy Policy. Seats are limited: if you are unable to attend, we kindly ask you to inform us as soon as possible at ias@ai4i.it
LINK ZOOM
AI4I
The Italian Institute of Artificial Intelligence (AI4I)
Corso Castelfidardo 22, 10129 Torino
Codice fiscale 97904430010
Partita IVA: 13130030011
ai4i@ai4i.it
ai4i@pro-pec.it


Copyright © 2025 AI4I Foundation – Privacy & Cookies